Smendiłendi
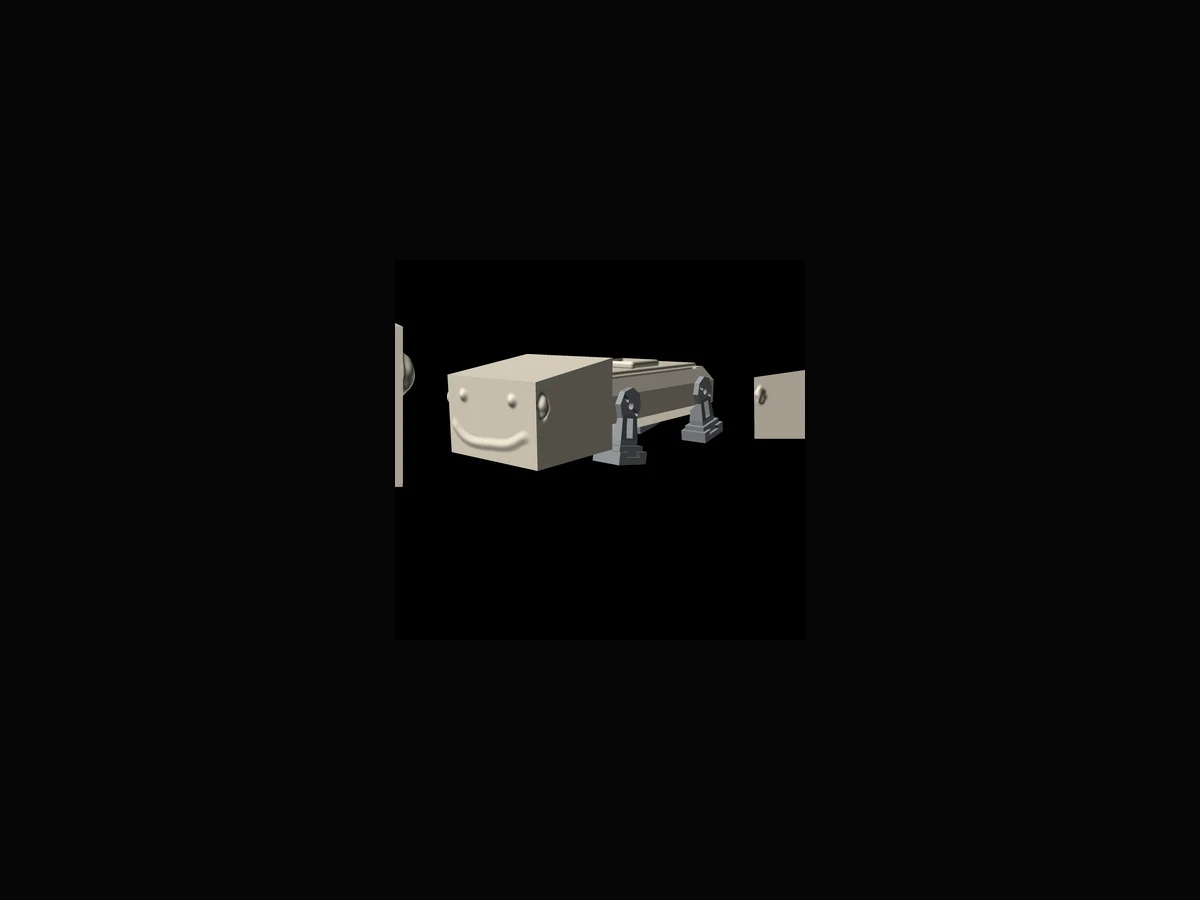
A printed robot dog on four servos and an ESP32, the first project here whose output is a physical object.
Not public yet
| Status | Building |
|---|---|
| Kind | Hardware |
| Year | 2026 |
| Built with | OpenSCAD, ESP32, Bambu X1C |
A small, light quadruped printed on a Bambu Lab X1C in ordinary PLA, driven by four hobby servos and a microcontroller. The scope is poses, touch and simple movement rather than dynamic walking.
It is the first project here where the feedback loop needs a person. The model can be changed from a keyboard, but measuring whether the printed part actually fits requires somebody standing at the printer with calipers, and that changes how the work is planned.
Reviews
loading...
Guestbook.txt - Notepad
Gzowo Guide.exe
AI guide. It can make mistakes.